C4 numerical estimator controls

No model family or nuisance policy is selected here. Exact input and stopping semantics accompany every control.

Full method and records · Model campaign · Inspection hashes

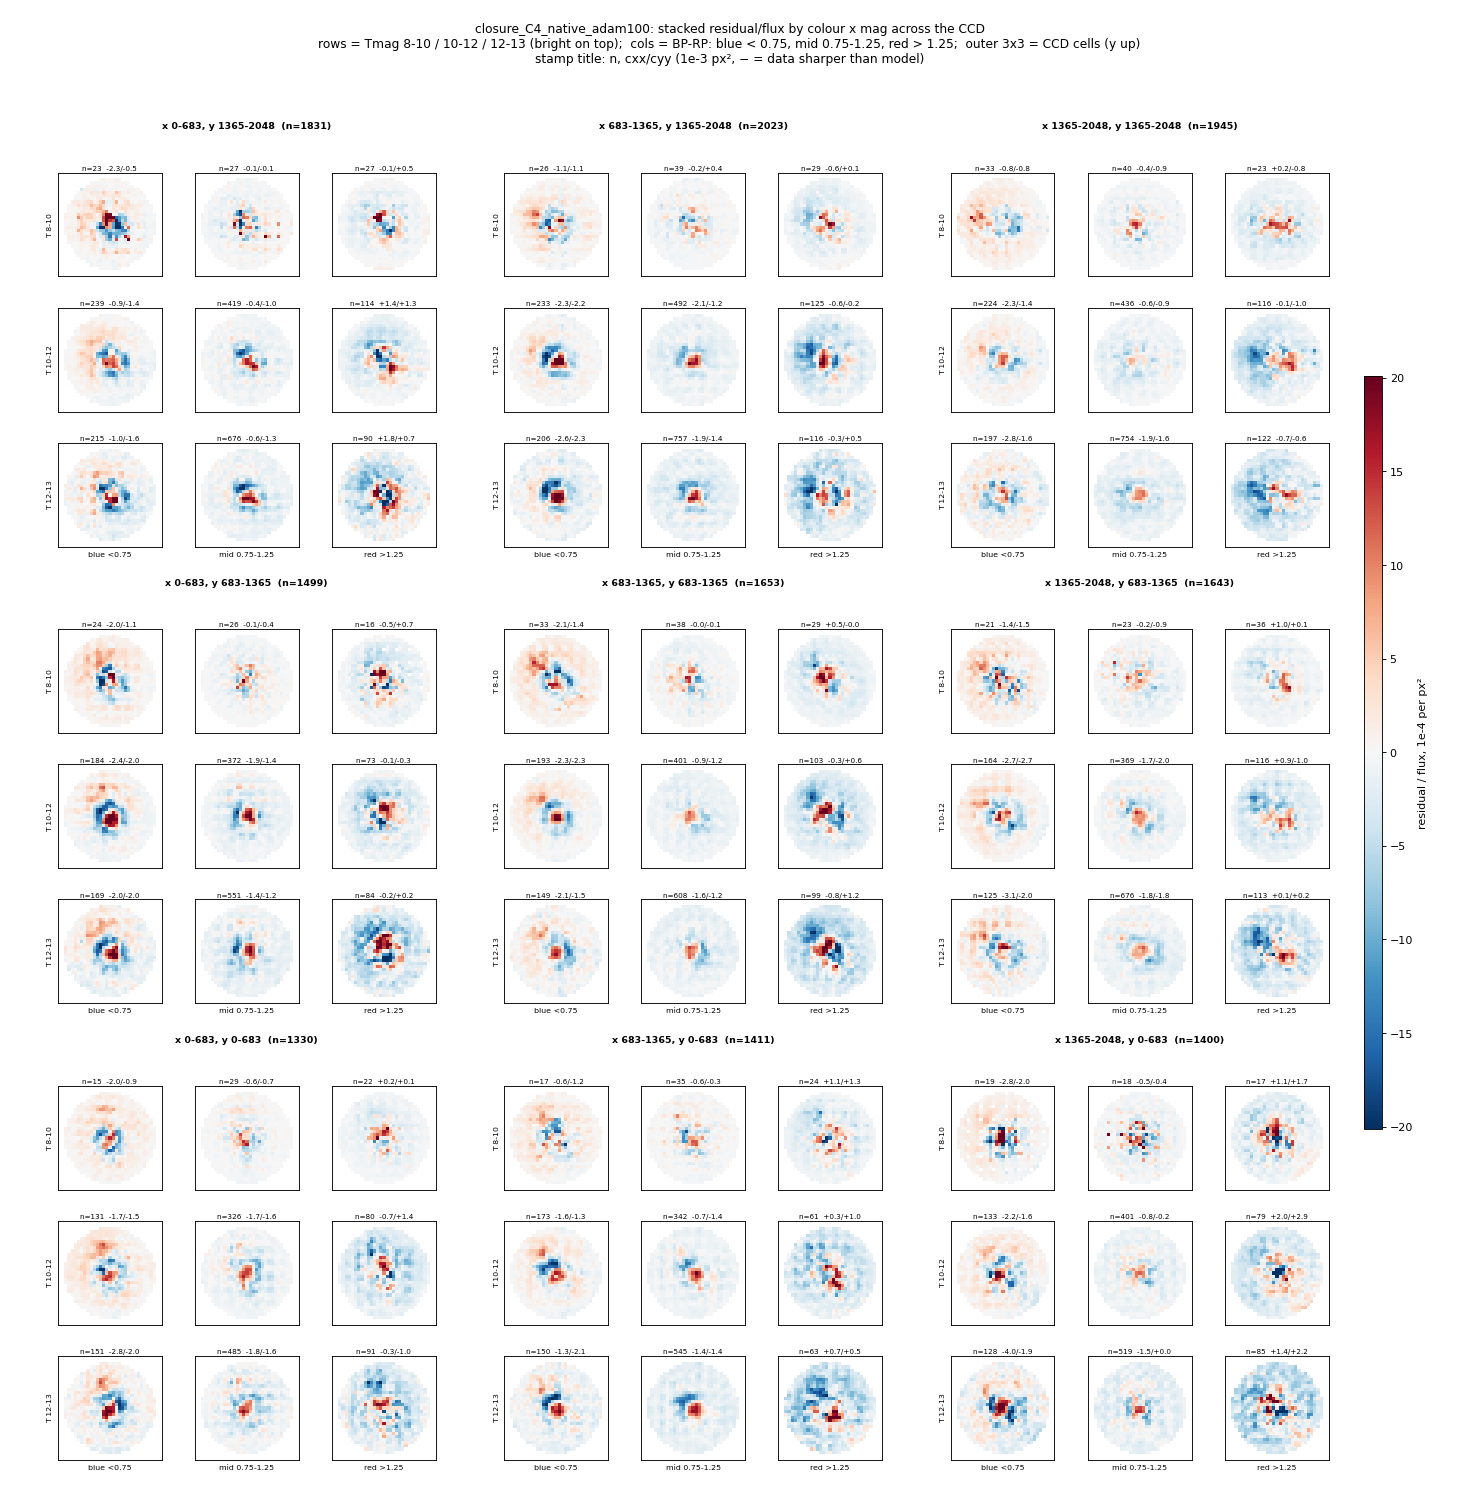
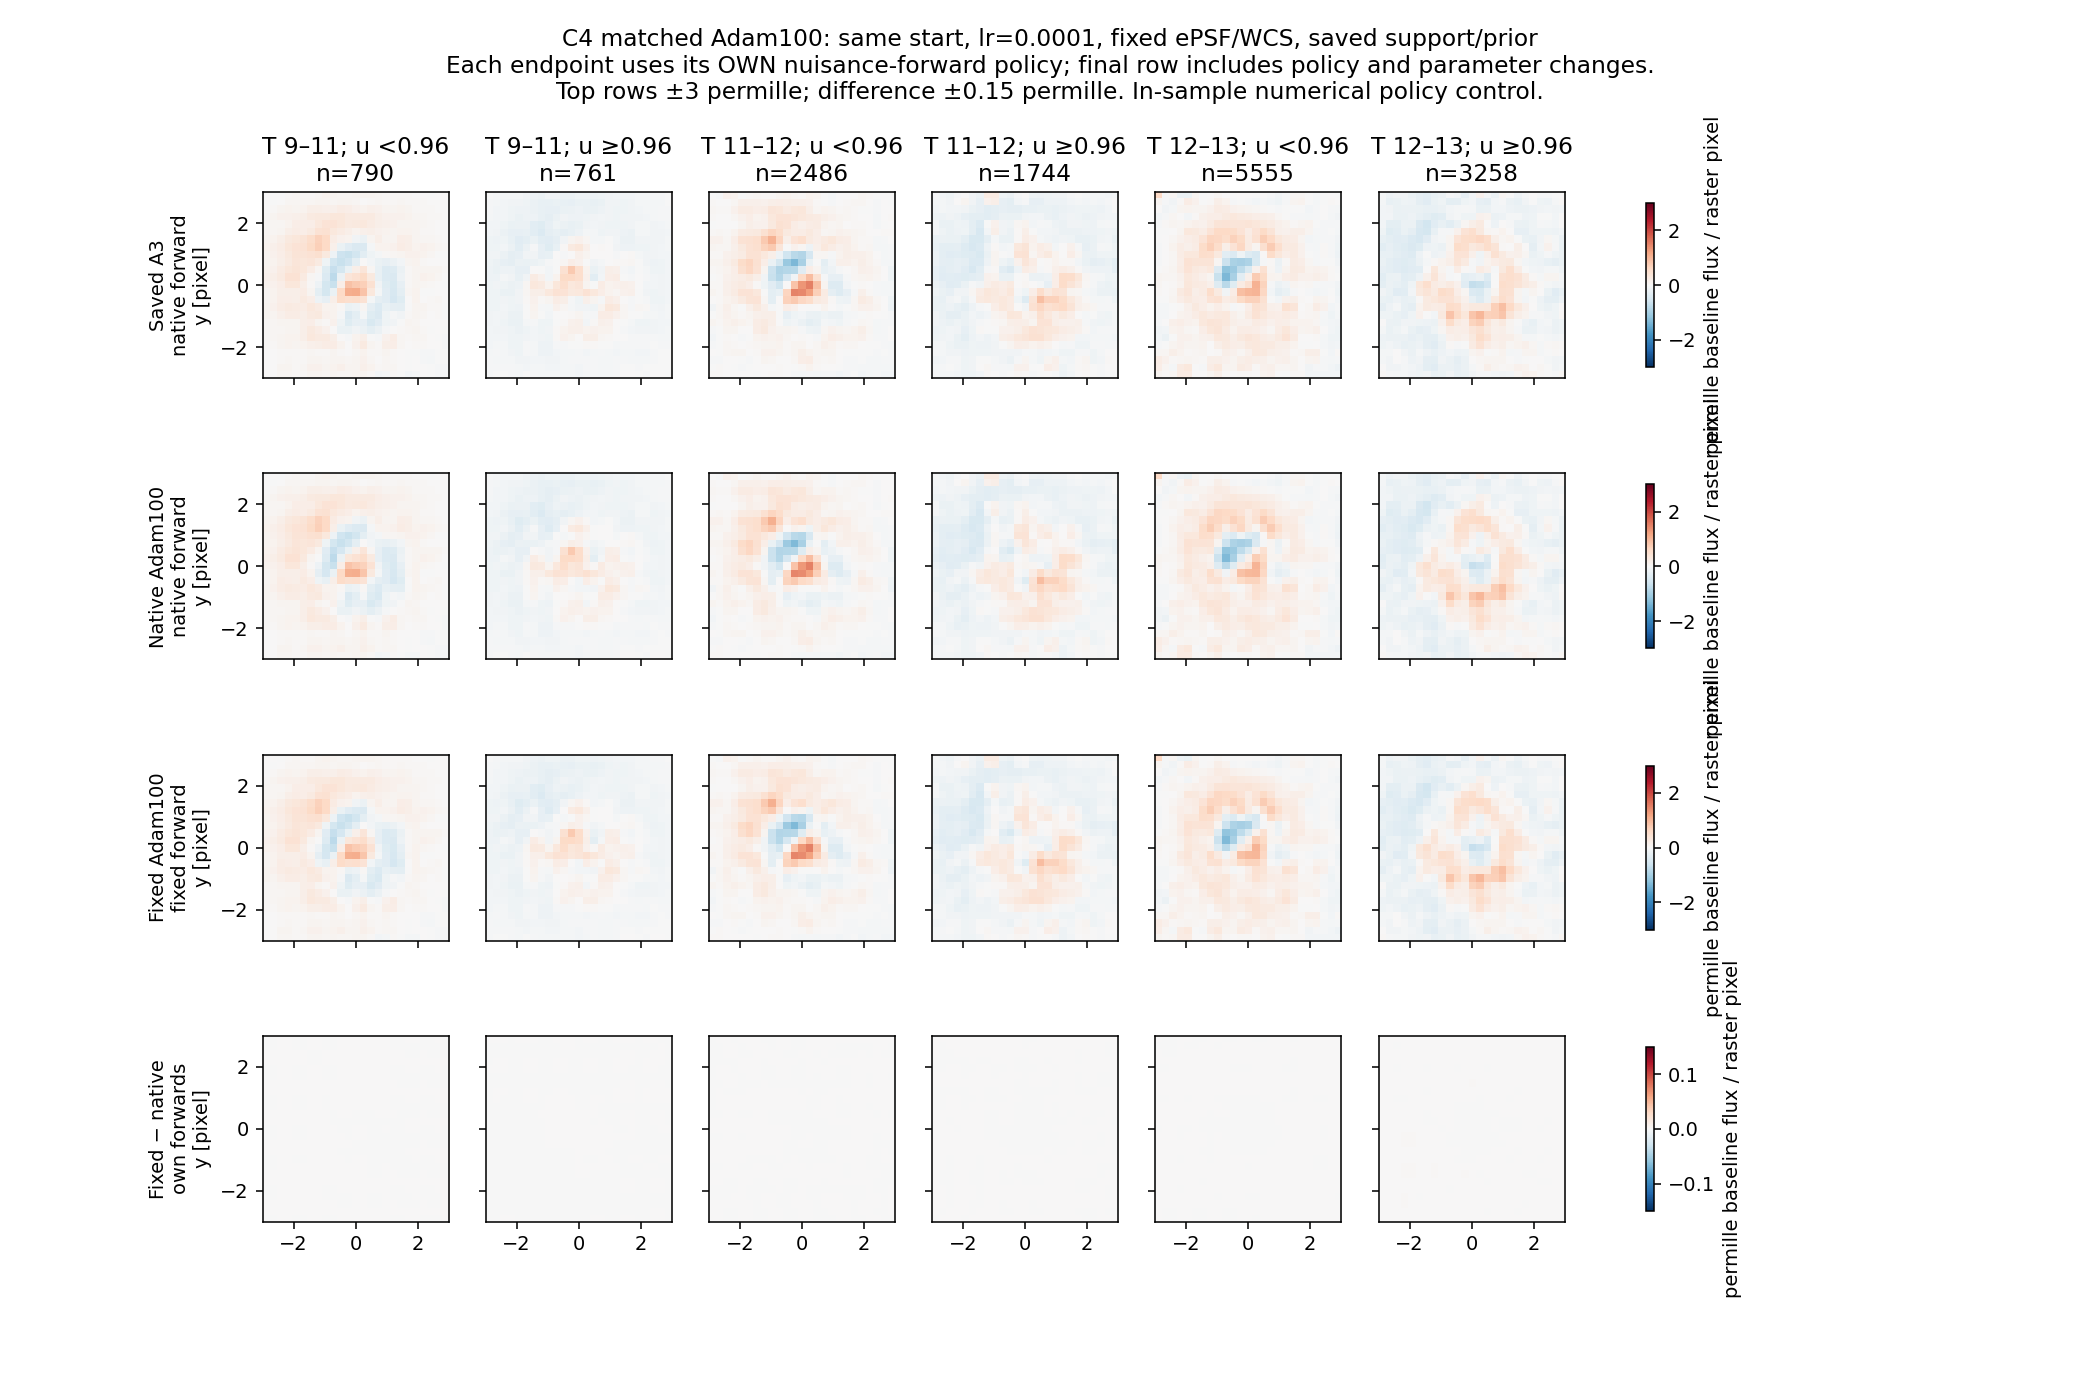
Matched100-step endpoints evaluated with their OWN nuisance-forward policies. Fixed minus native includes both policy and parameter changes.
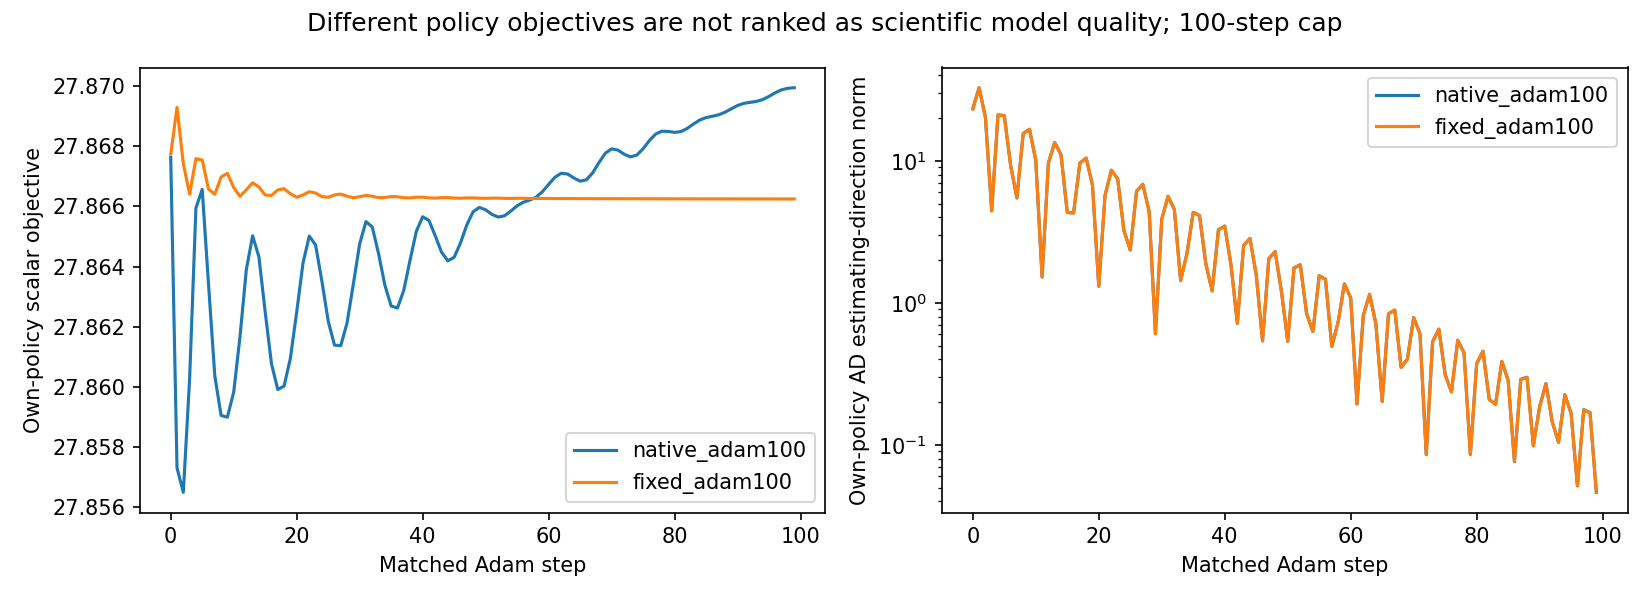
The native role estimator supplies a quasi-gradient; different scalar objectives cannot select a scientific model.
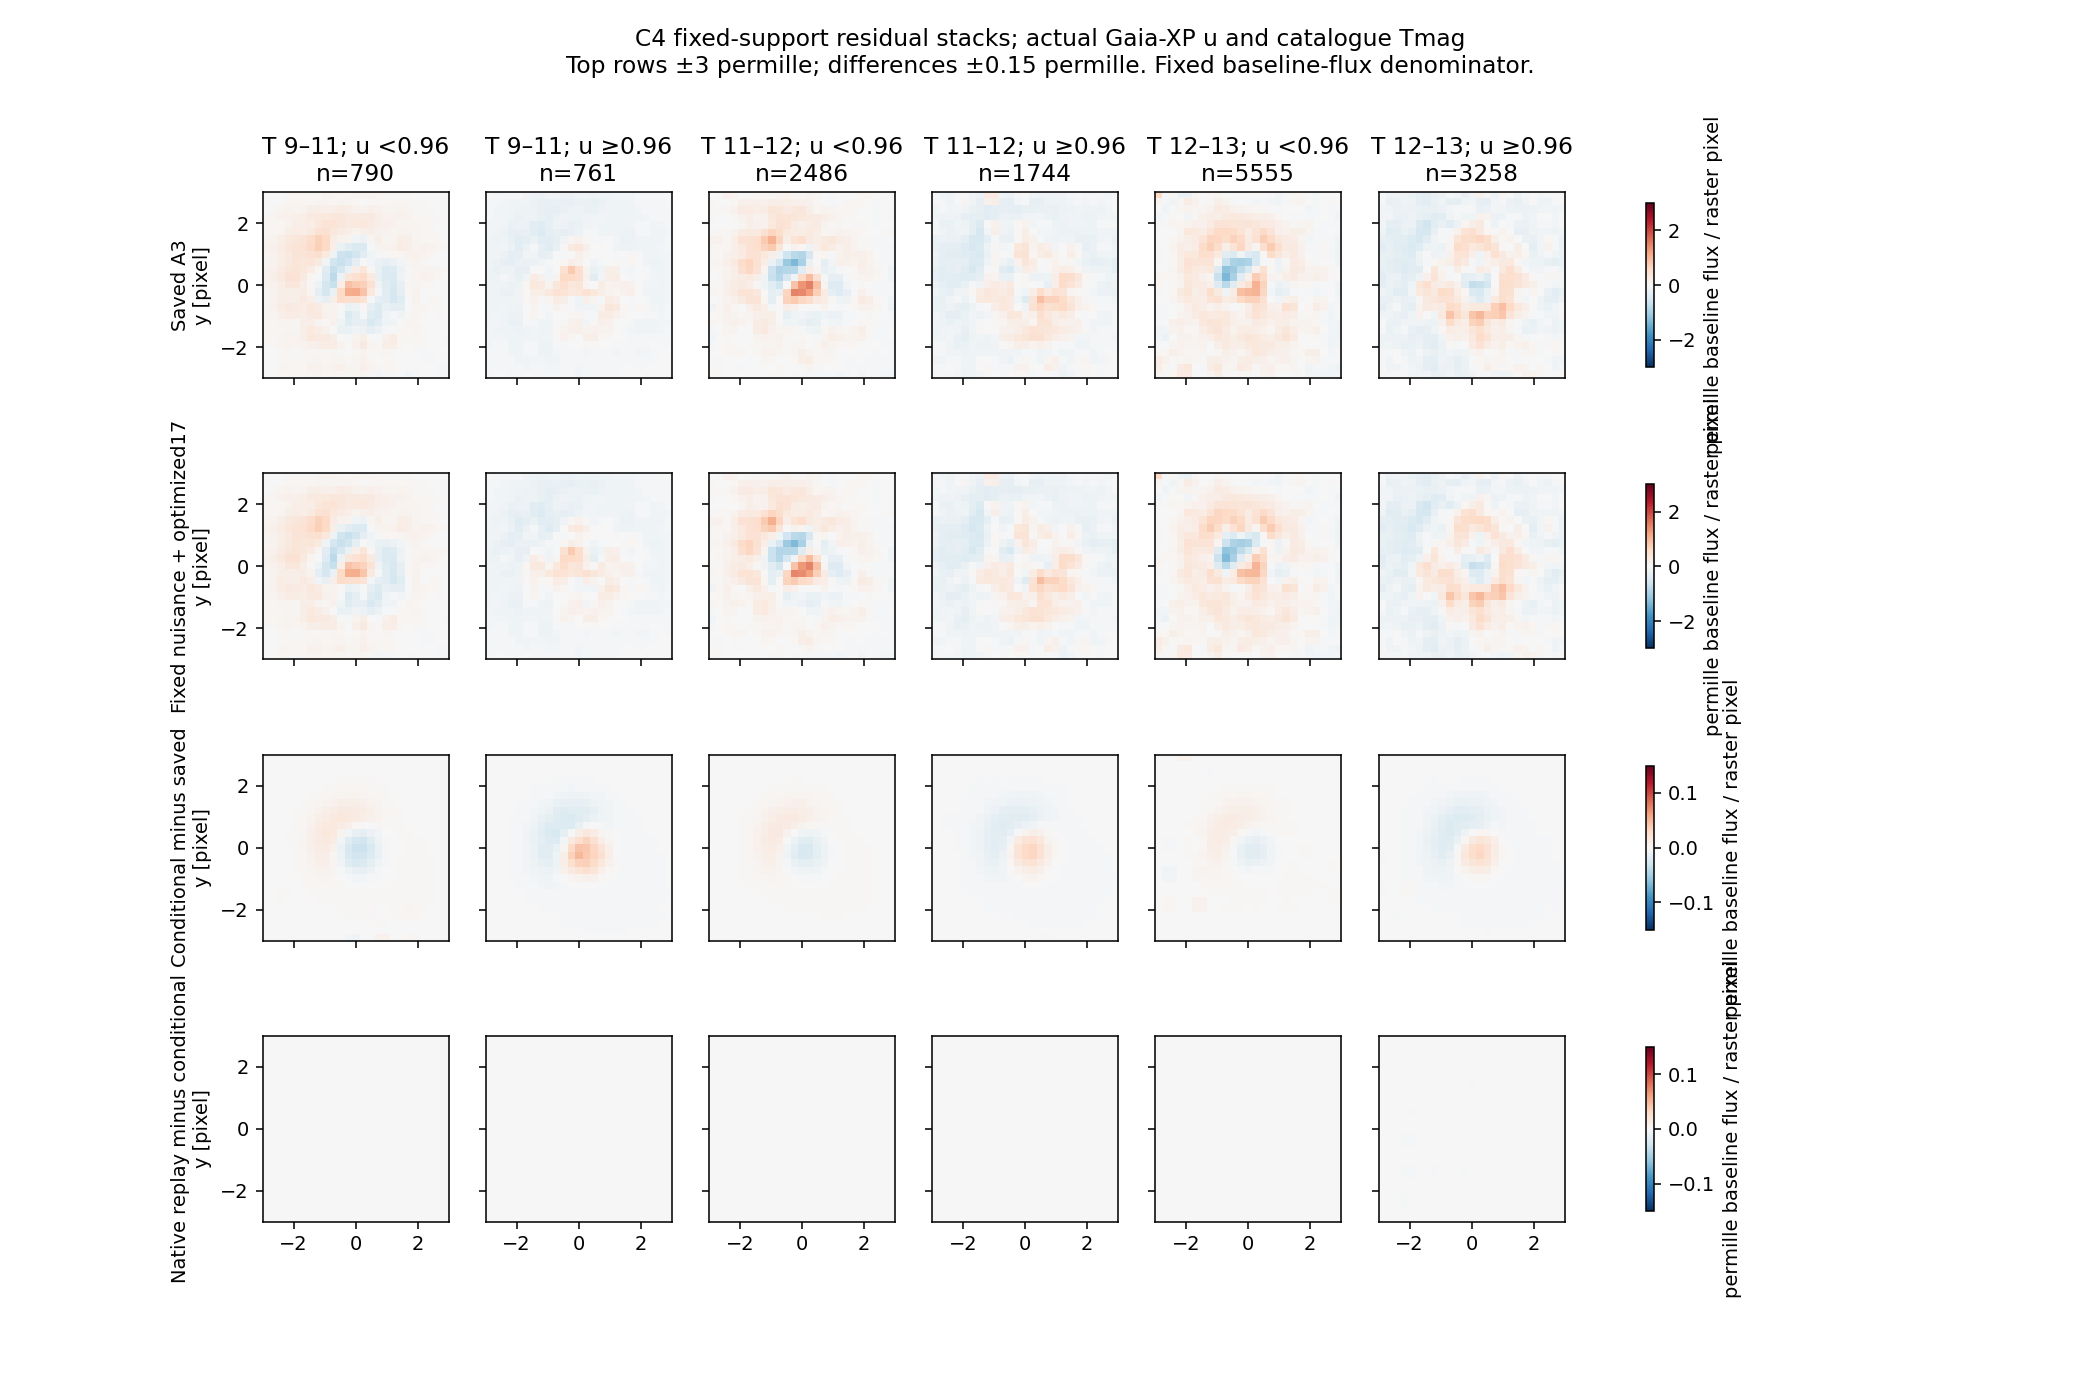
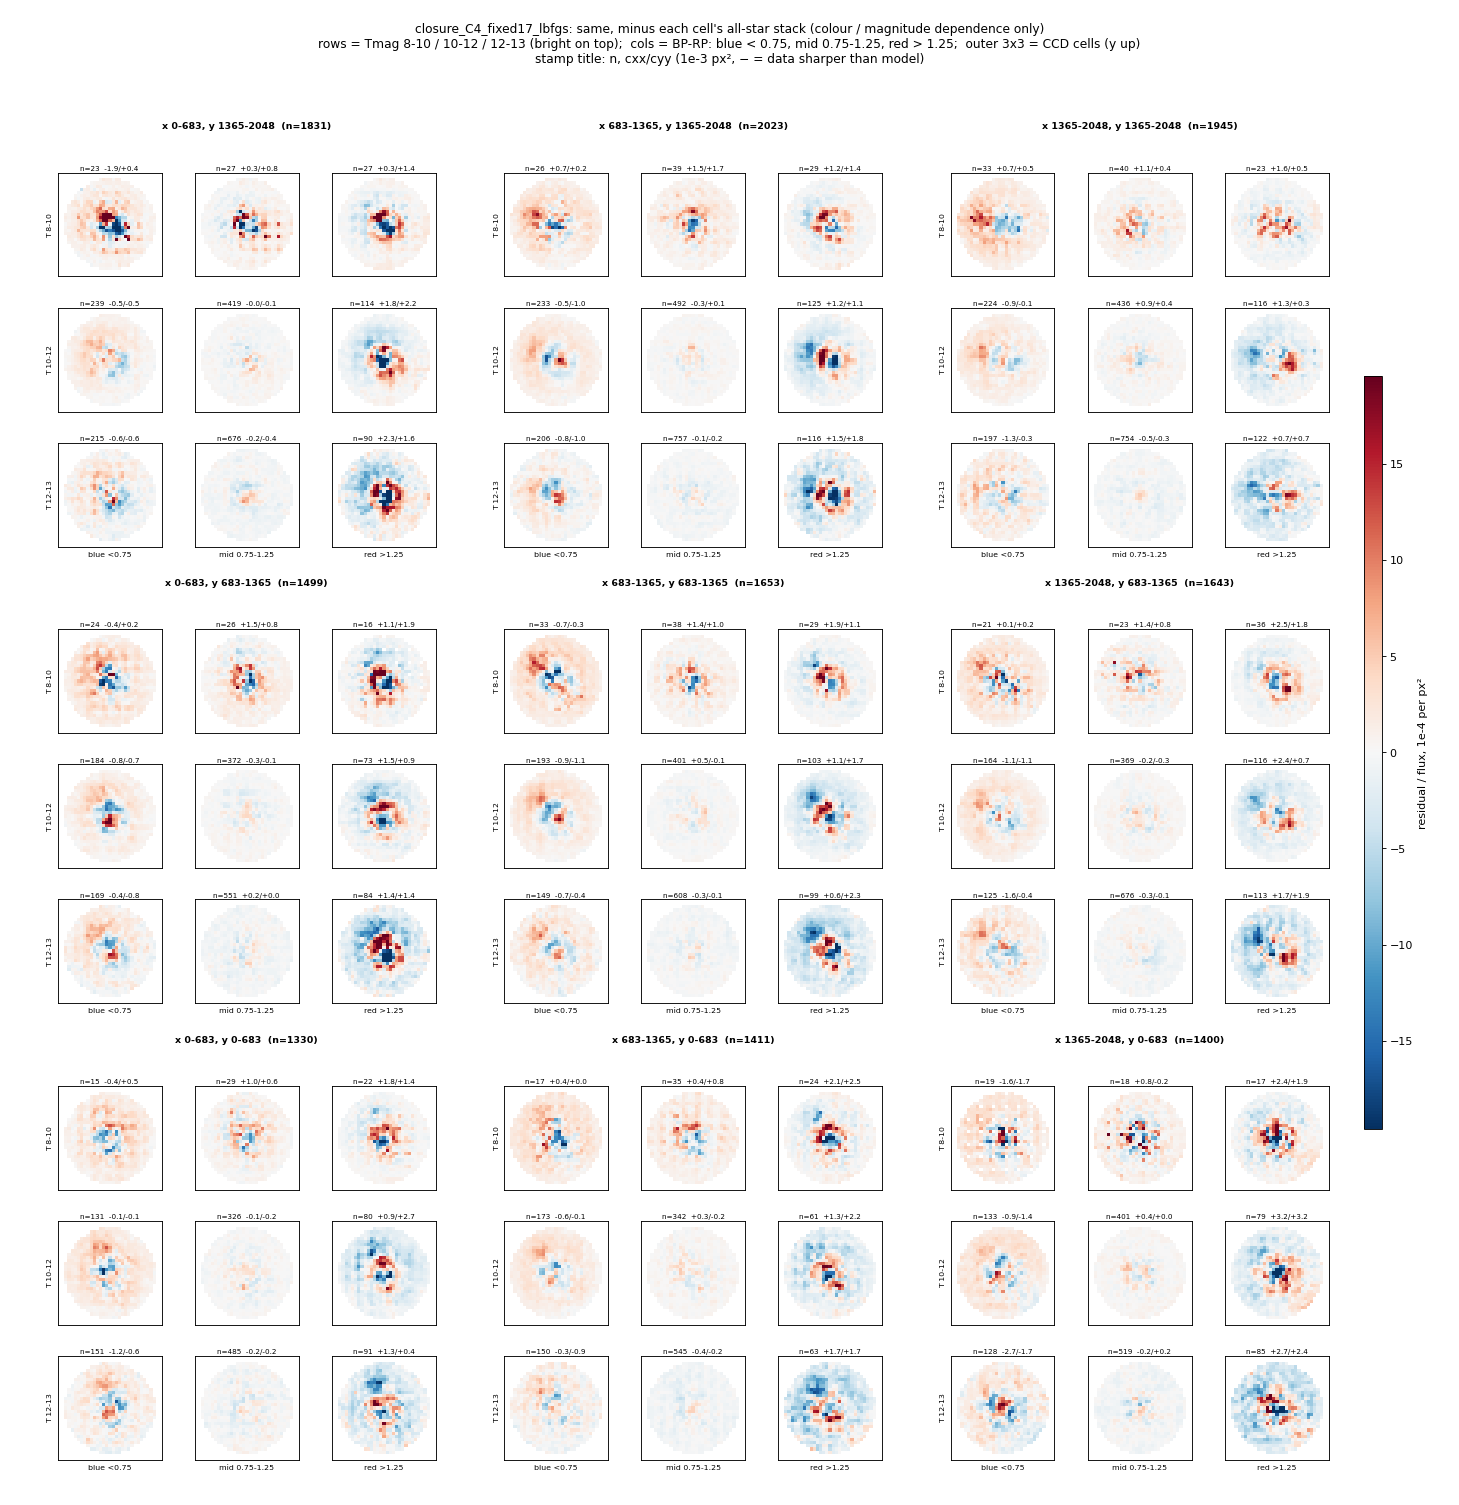
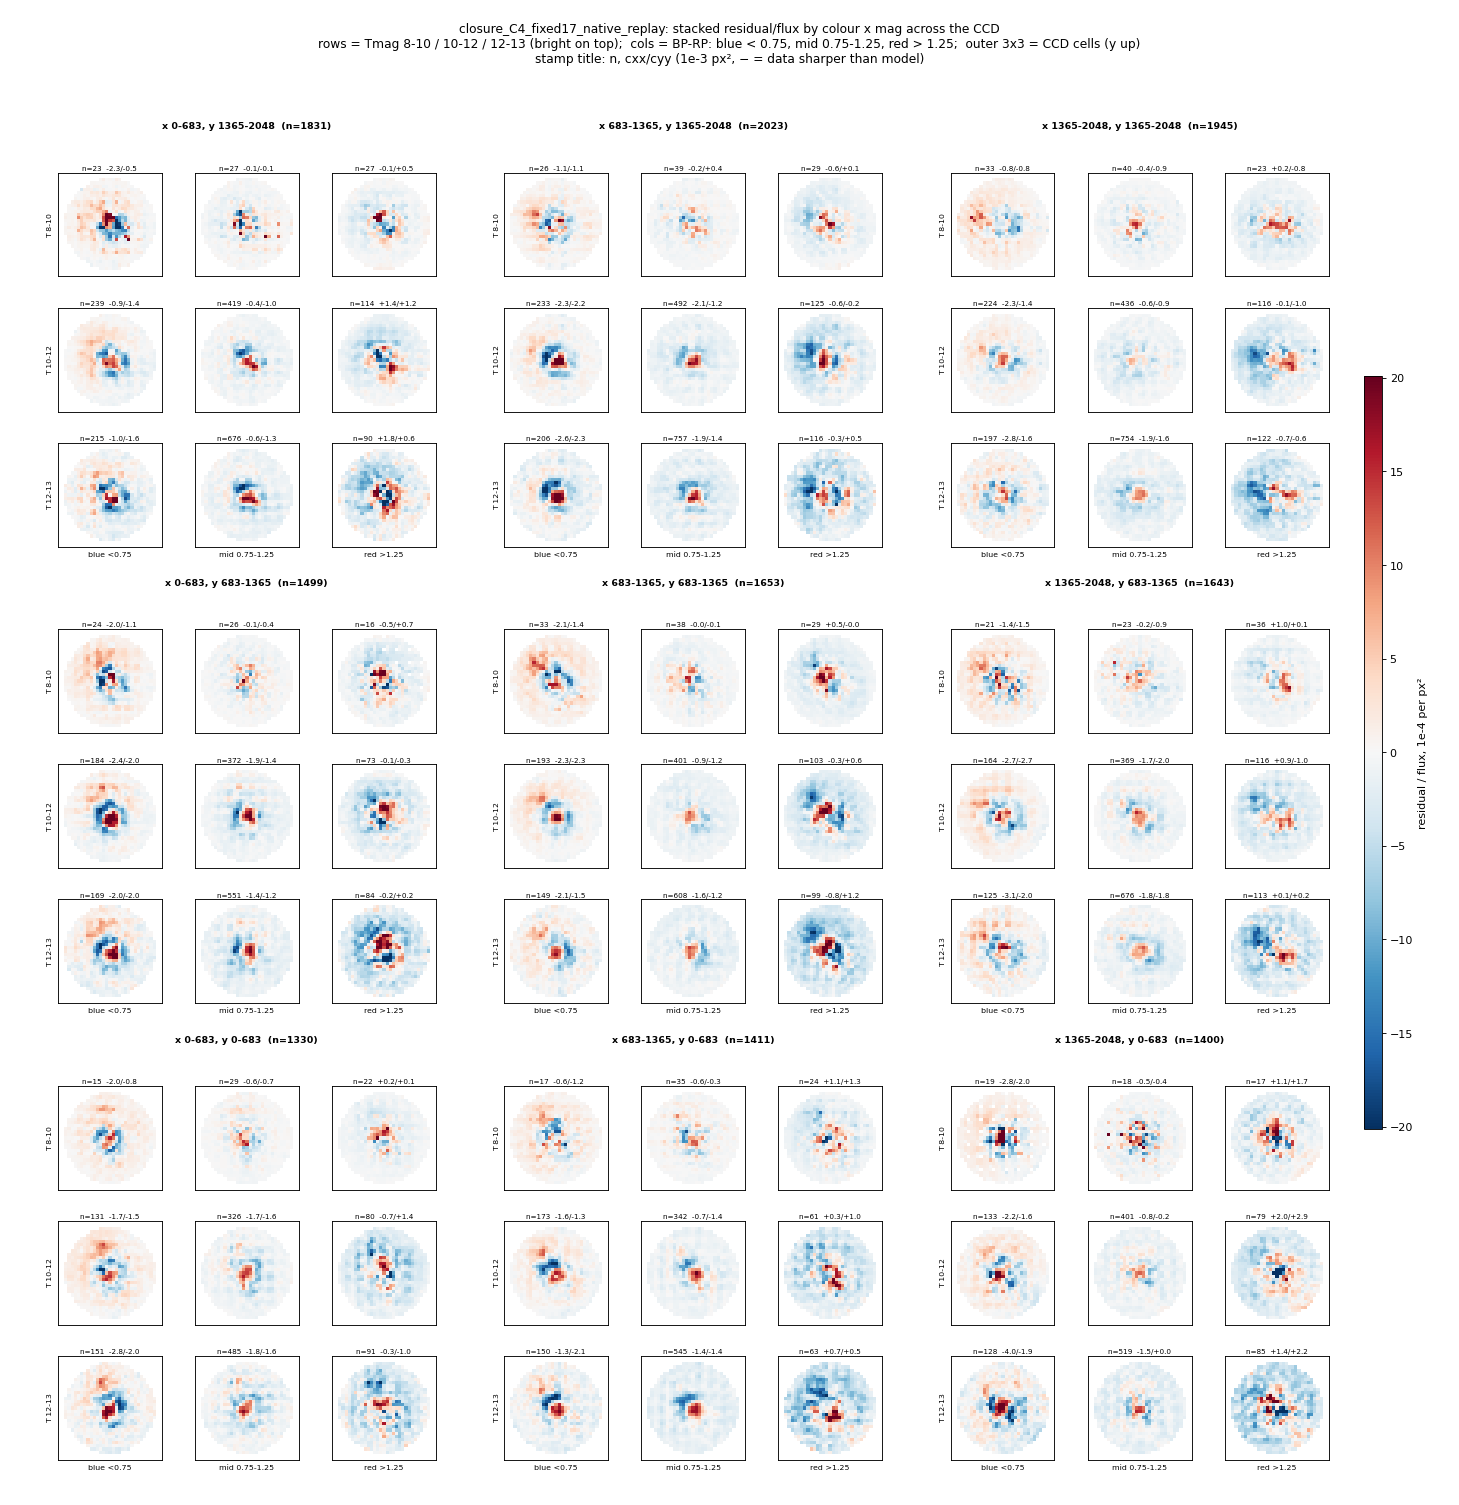
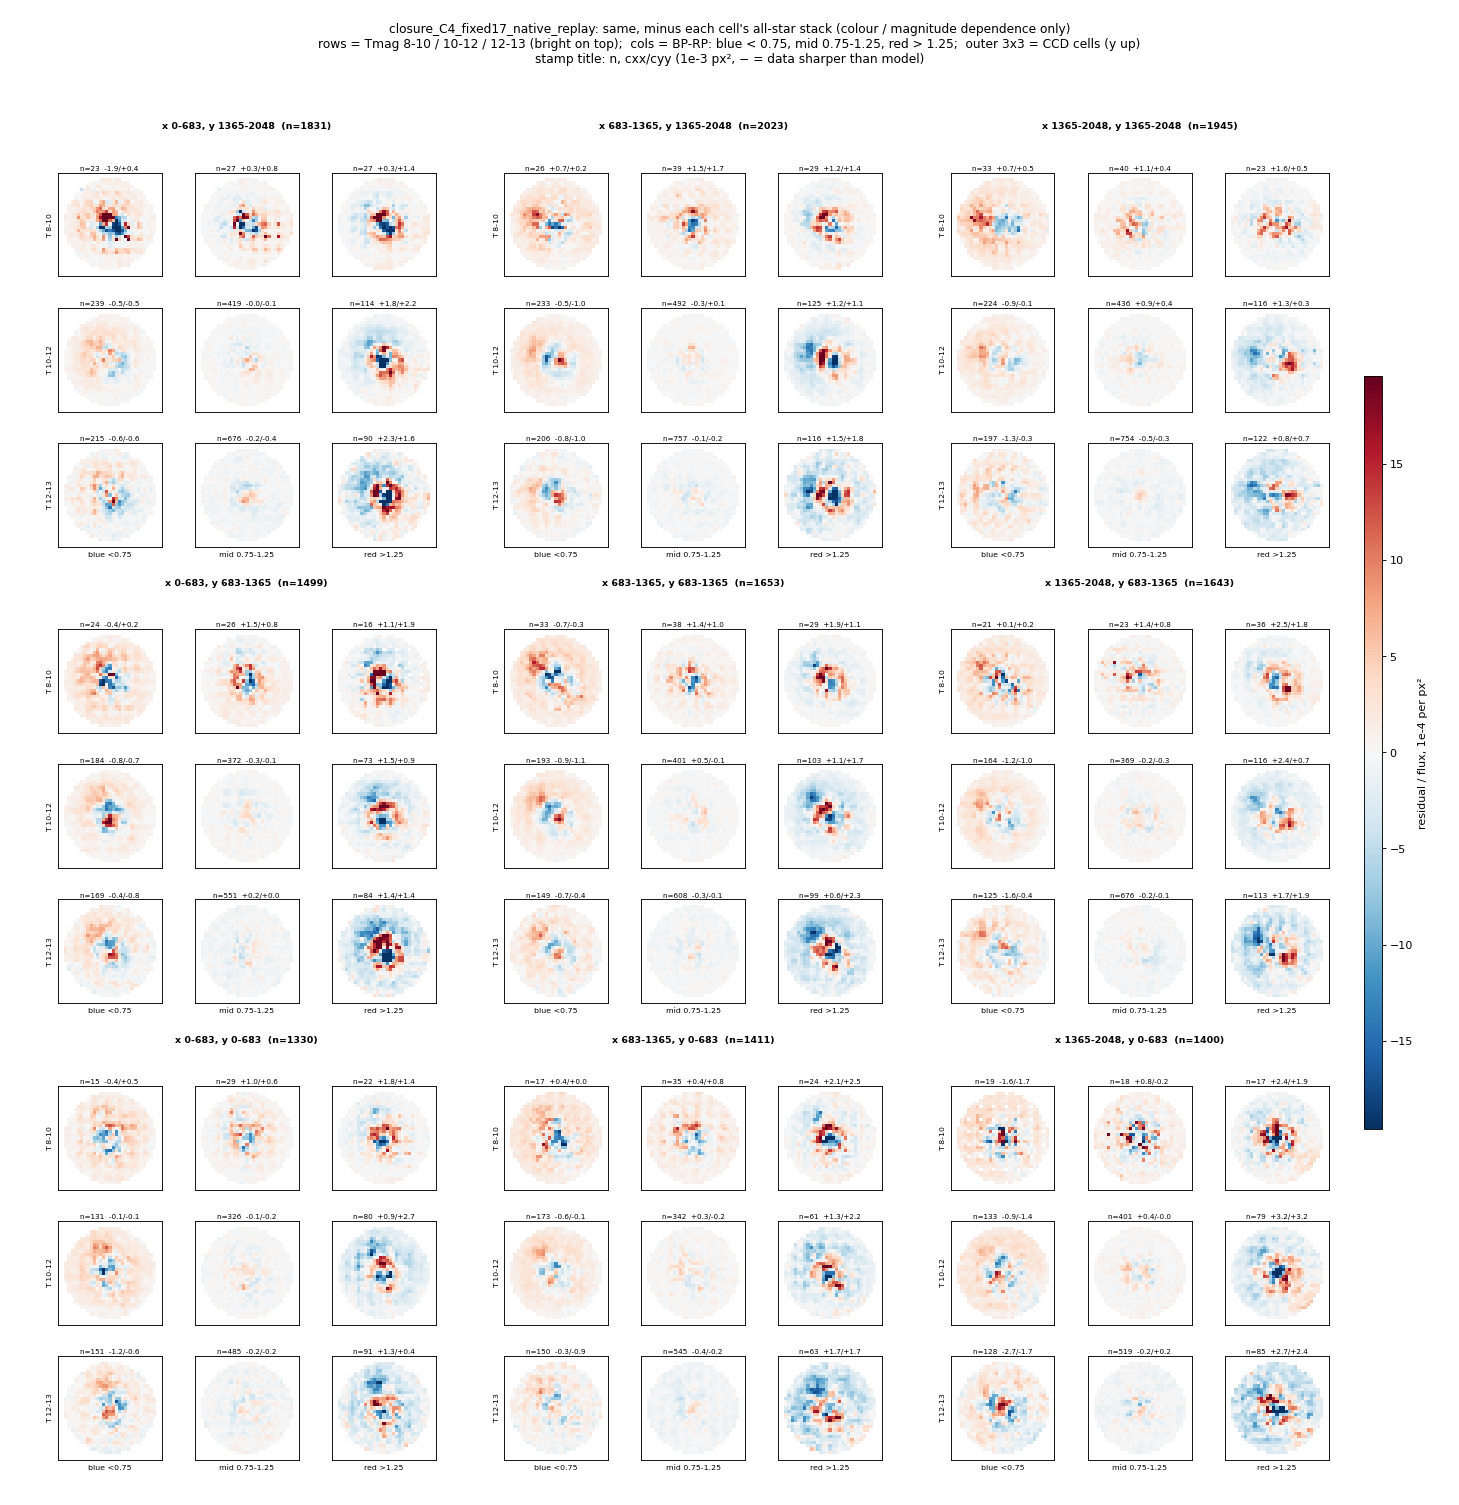
Original17-colour conditional optimization; underlying absolute and difference residual stacks on fixed support and denominator.
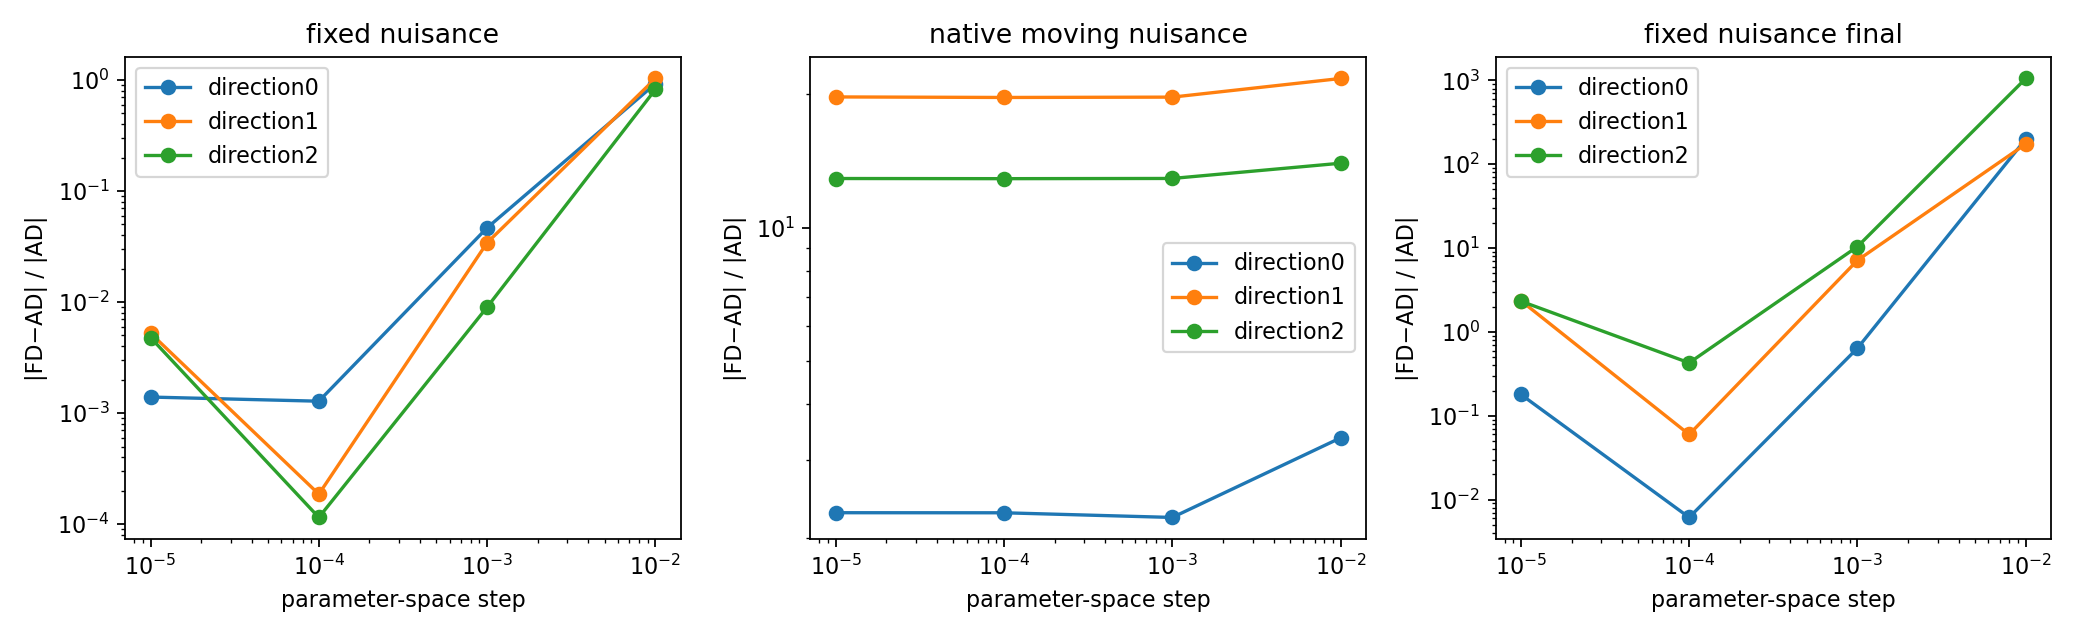
Directional finite differences validate the fixed-nuisance colour-only scalar objective initially; the native moving-nuisance quasi-gradient has different semantics.
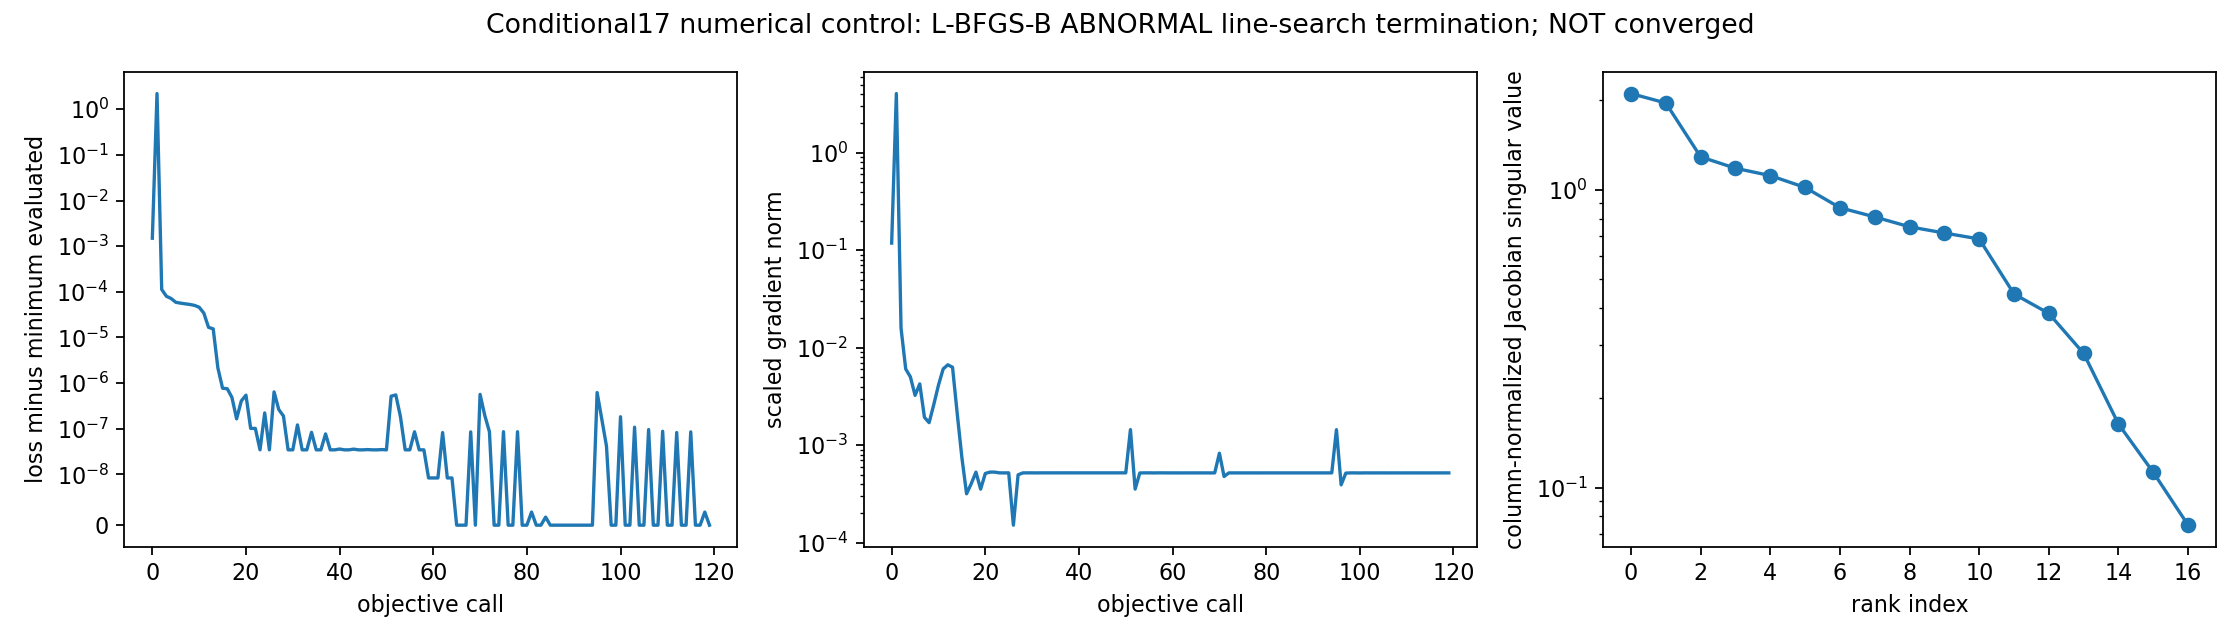
L-BFGS-B ended ABNORMAL at a precision plateau. No stationary-fit claim.
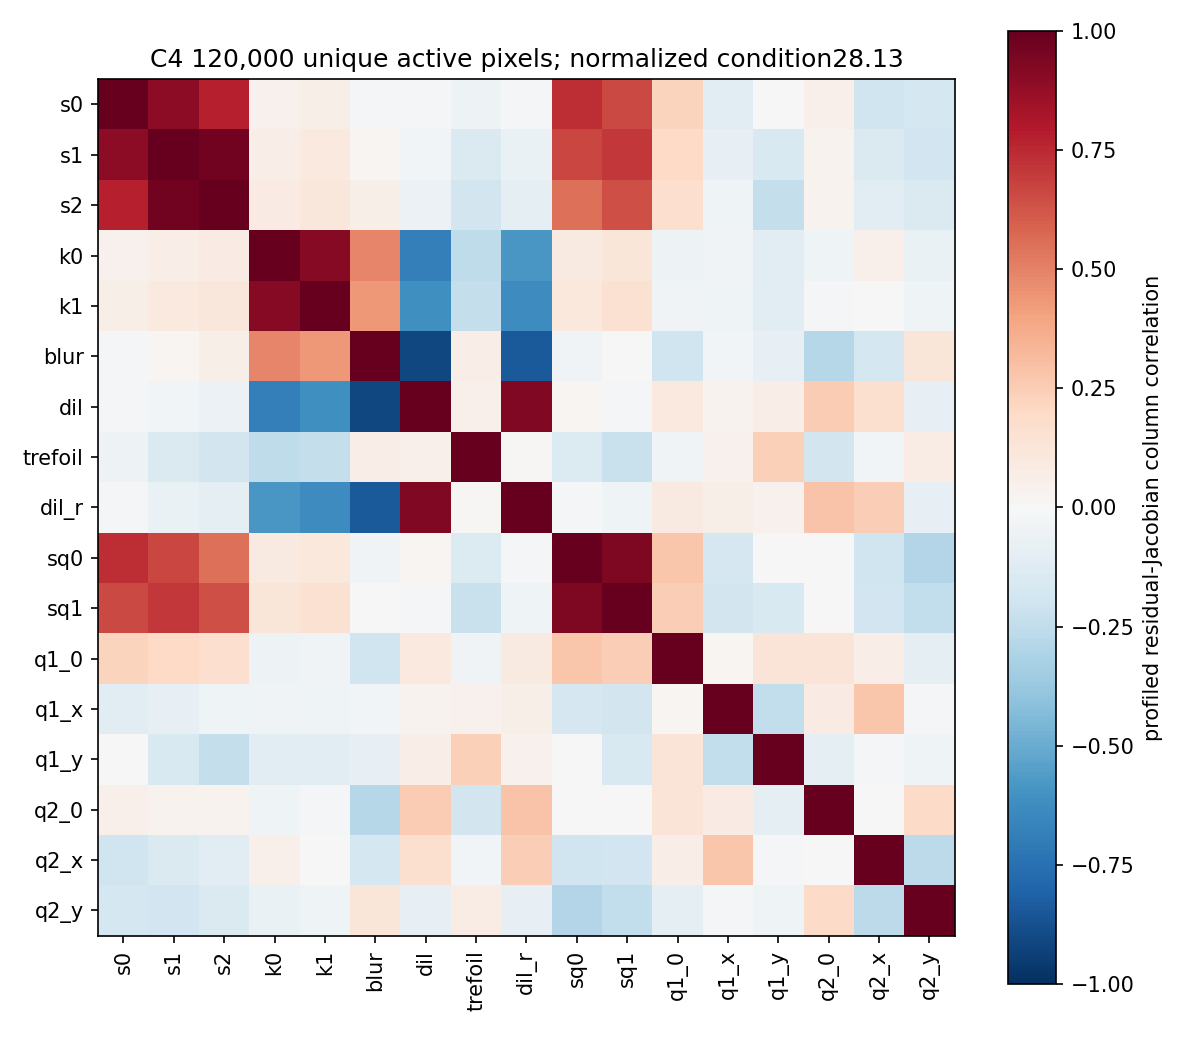
Conditional17-colour derivative correlations, holding ePSF and WCS fixed.
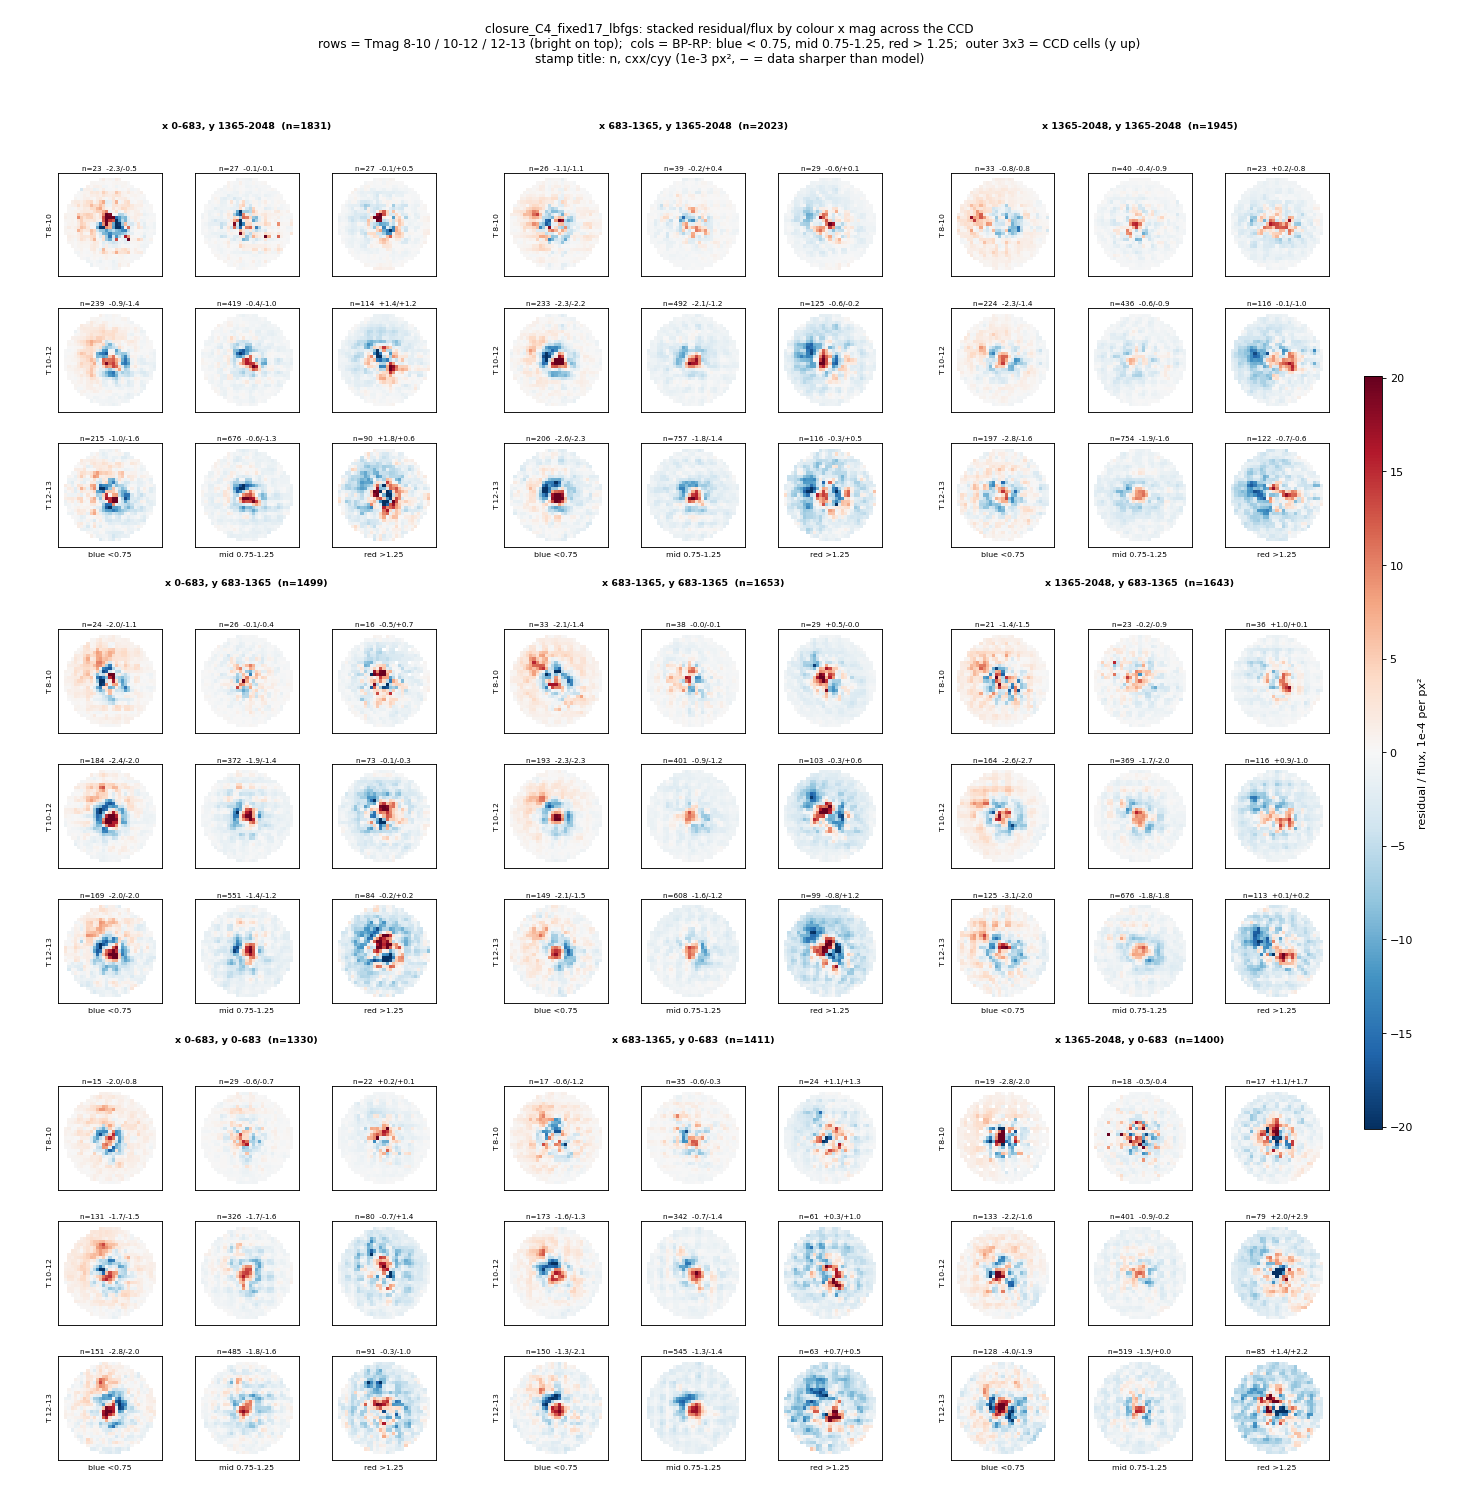
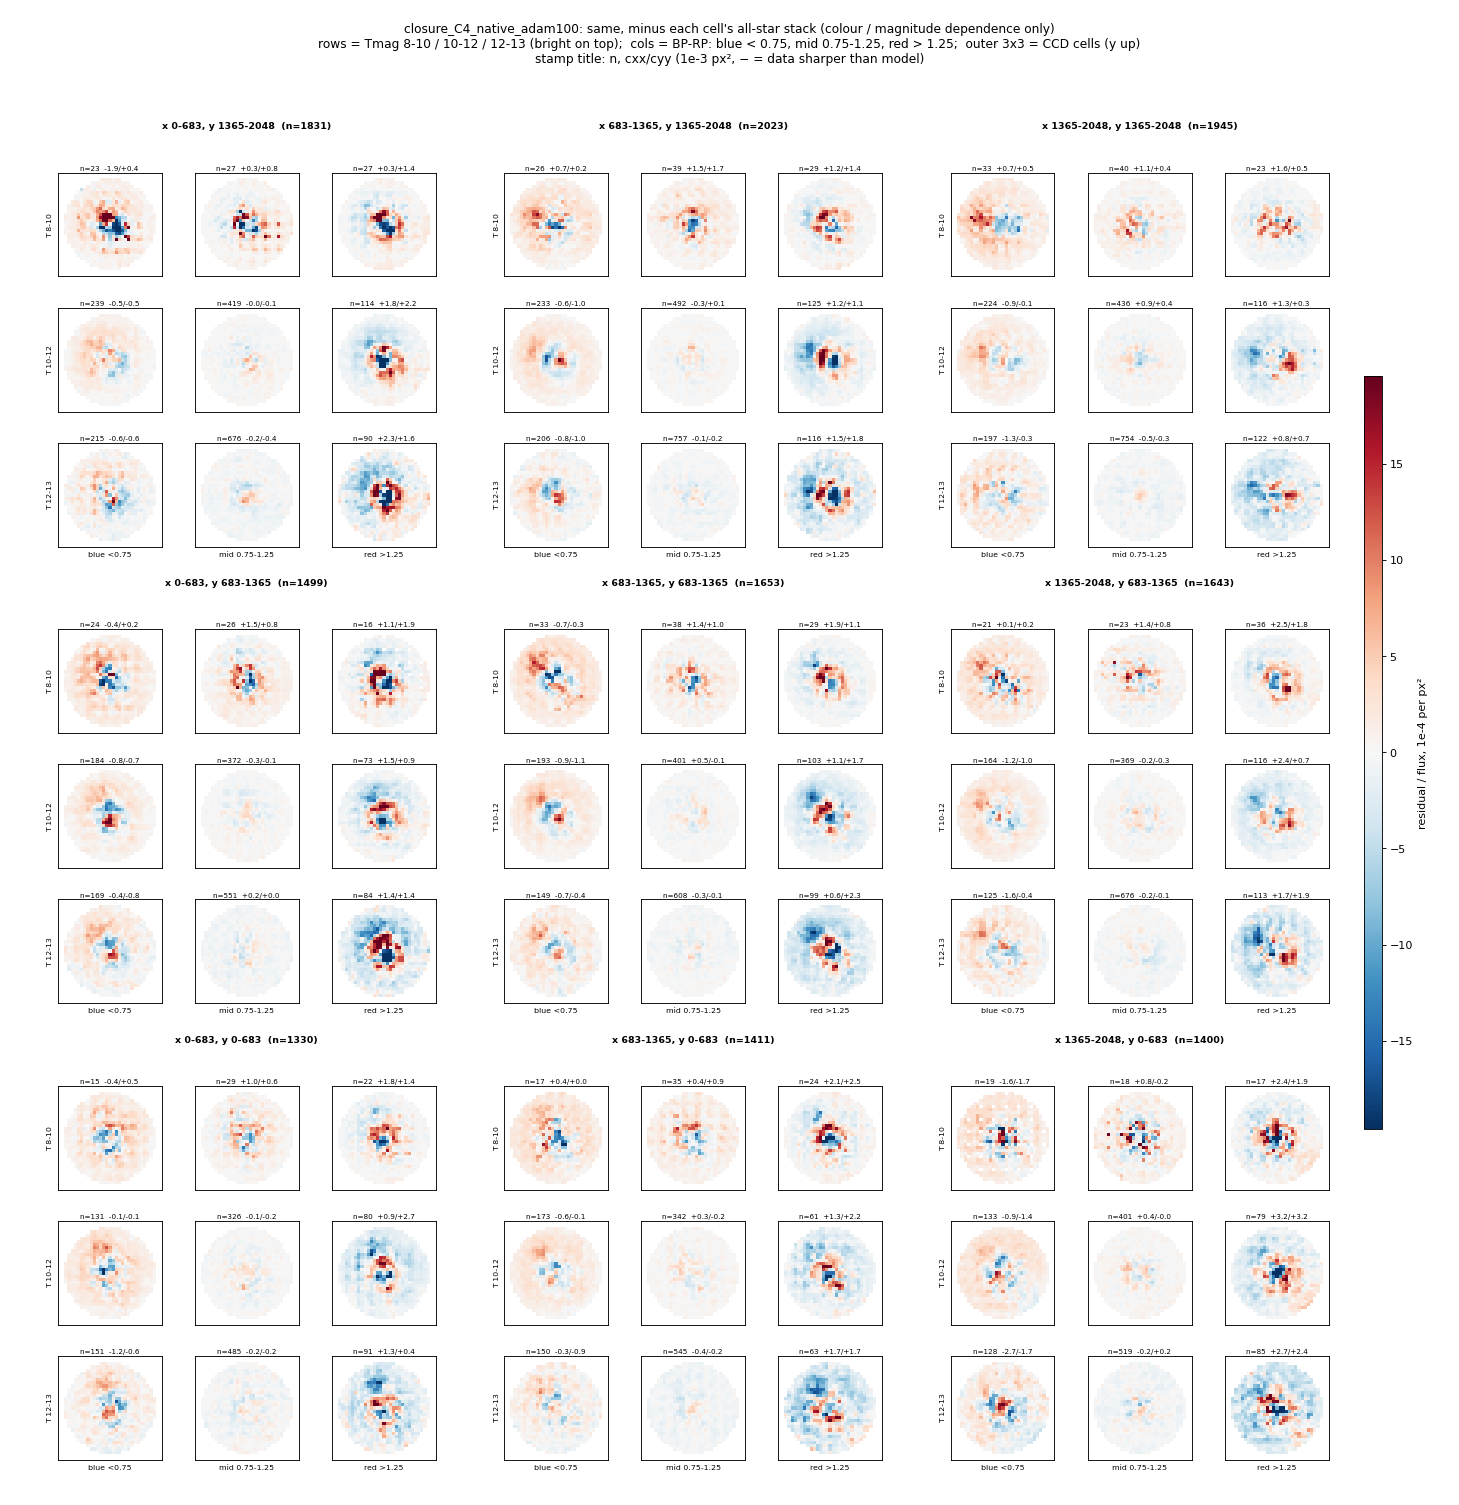
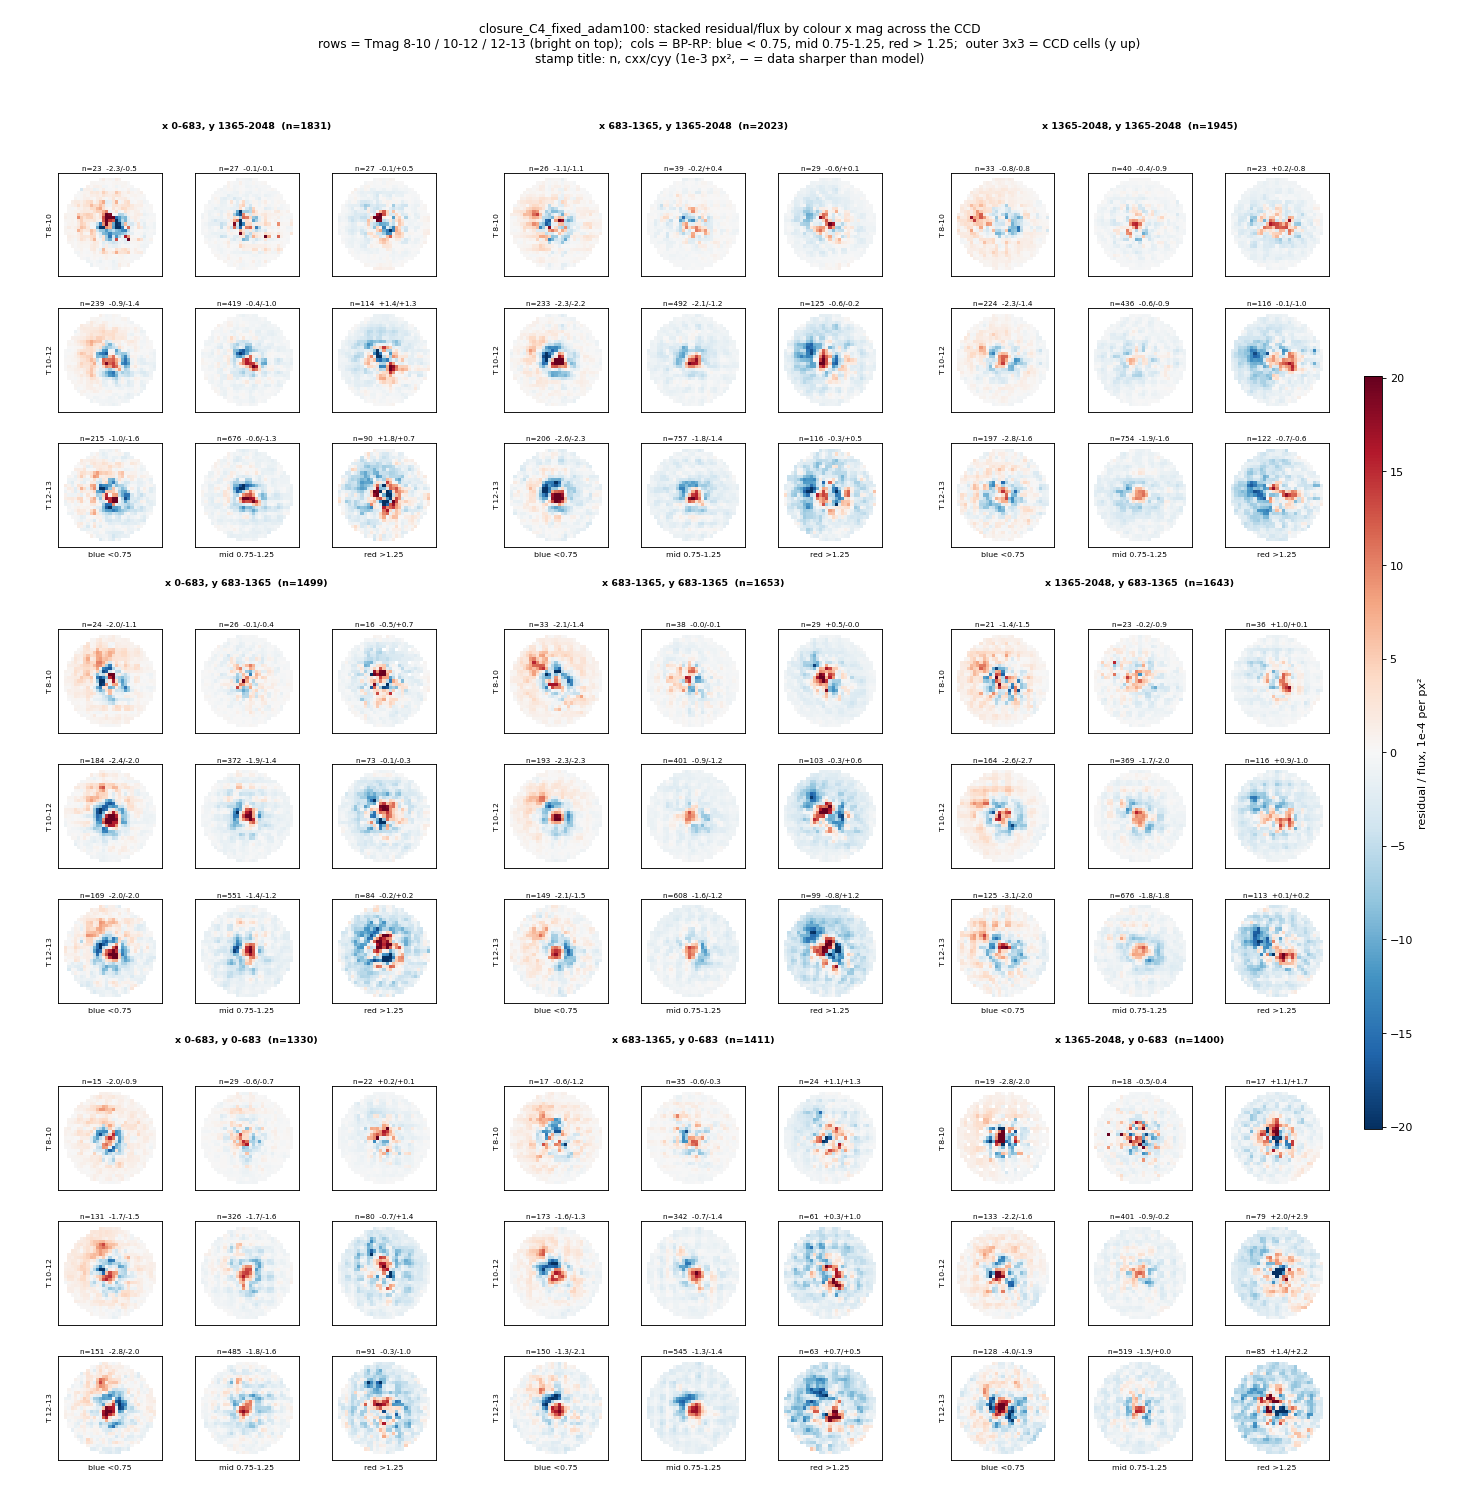
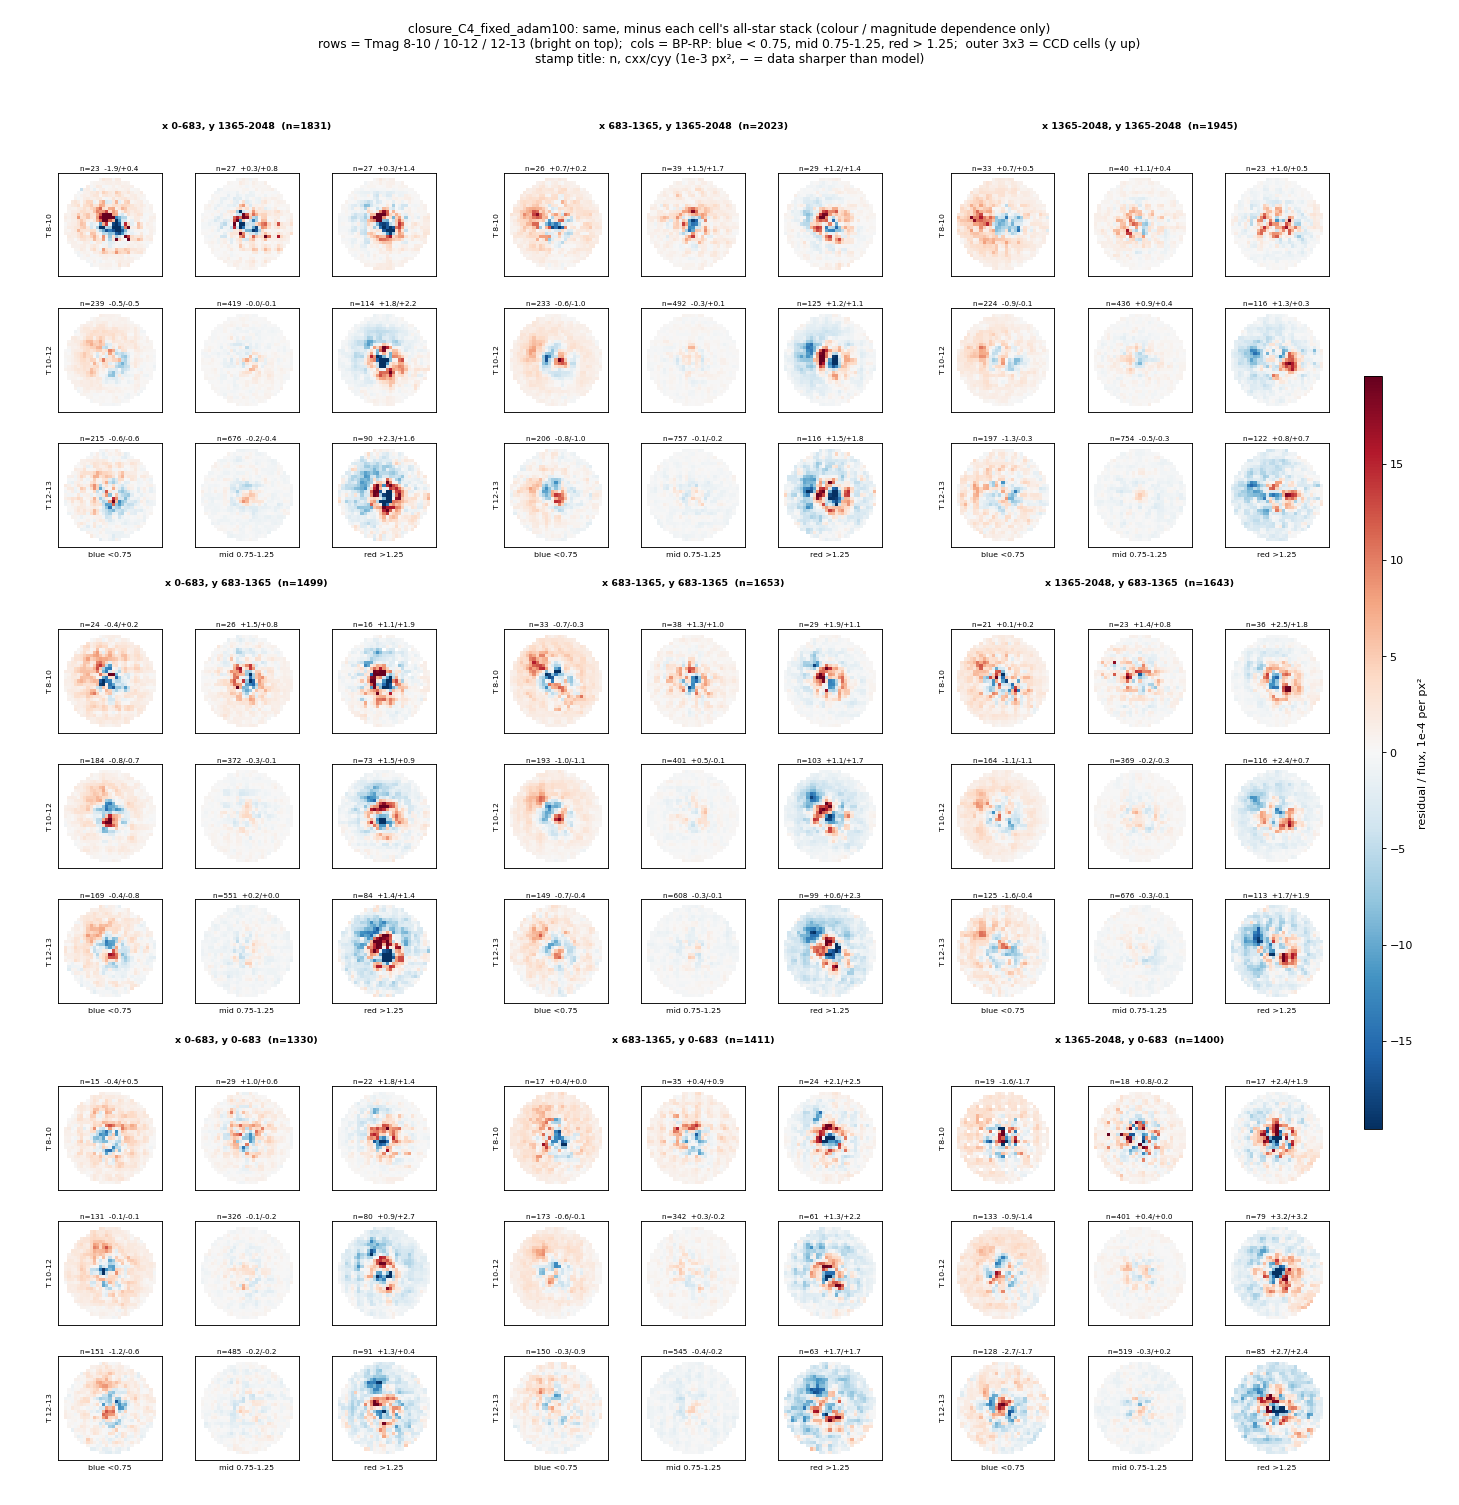
Legacy BP-RP/baseline-amplitude Tmag grid; in-sample numerical control. Relative grid subtracts each spatial-cell population.